
Case Study: High performance simulation
Partner: Amazon Web Services
Challenge
Amazon Web Services (AWS) sought to demonstrate how cloud-native robotics simulation can scale using Open 3D Engine (O3DE) and ROS 2, enabling developers to run high-fidelity environments, multi-robot scenarios, and distributed sensor simulation at massive scale. To support this vision, AWS needed a realistic, performant, and extensible robotics demo showcasing how modern game-engine-grade graphics and physics could integrate seamlessly with ROS 2 and cloud compute resources.
Key challenges included:
- Bridging game-engine rendering with robotics simulation through ROS 2-native interfaces.
- Simulating multiple robots and sensors in real time, with realistic LiDAR, camera, and physics behavior.
- Creating a reusable demonstration showing O3DE’s scalability, modularity, and cloud-deployment potential.
- Ensuring ROS 2 compatibility across navigation, perception, and control pipelines.
Solution
Robotec.ai partnered with AWS to build an end-to-end robotics simulation demo using Open 3D Engine, ROS 2, and the Robotec GPU Lidar (RGL) Library. The demo showcased how O3DE can serve as a scalable, cloud-ready simulator capable of powering complex multi-robot systems.
Key enhancements:
- O3DE-ROS 2 Integration Layer: Implemented and refined ROS 2 communication bindings for O3DE, enabling real-time exchange of transforms, sensor data, navigation messages, and robot state updates.
- GPU-Accelerated LiDAR Simulation: Integrated the Robotec GPU Lidar (RGL) Library to deliver high-fidelity, multi-beam LiDAR scans with minimal performance overhead – crucial for multi-robot demos.
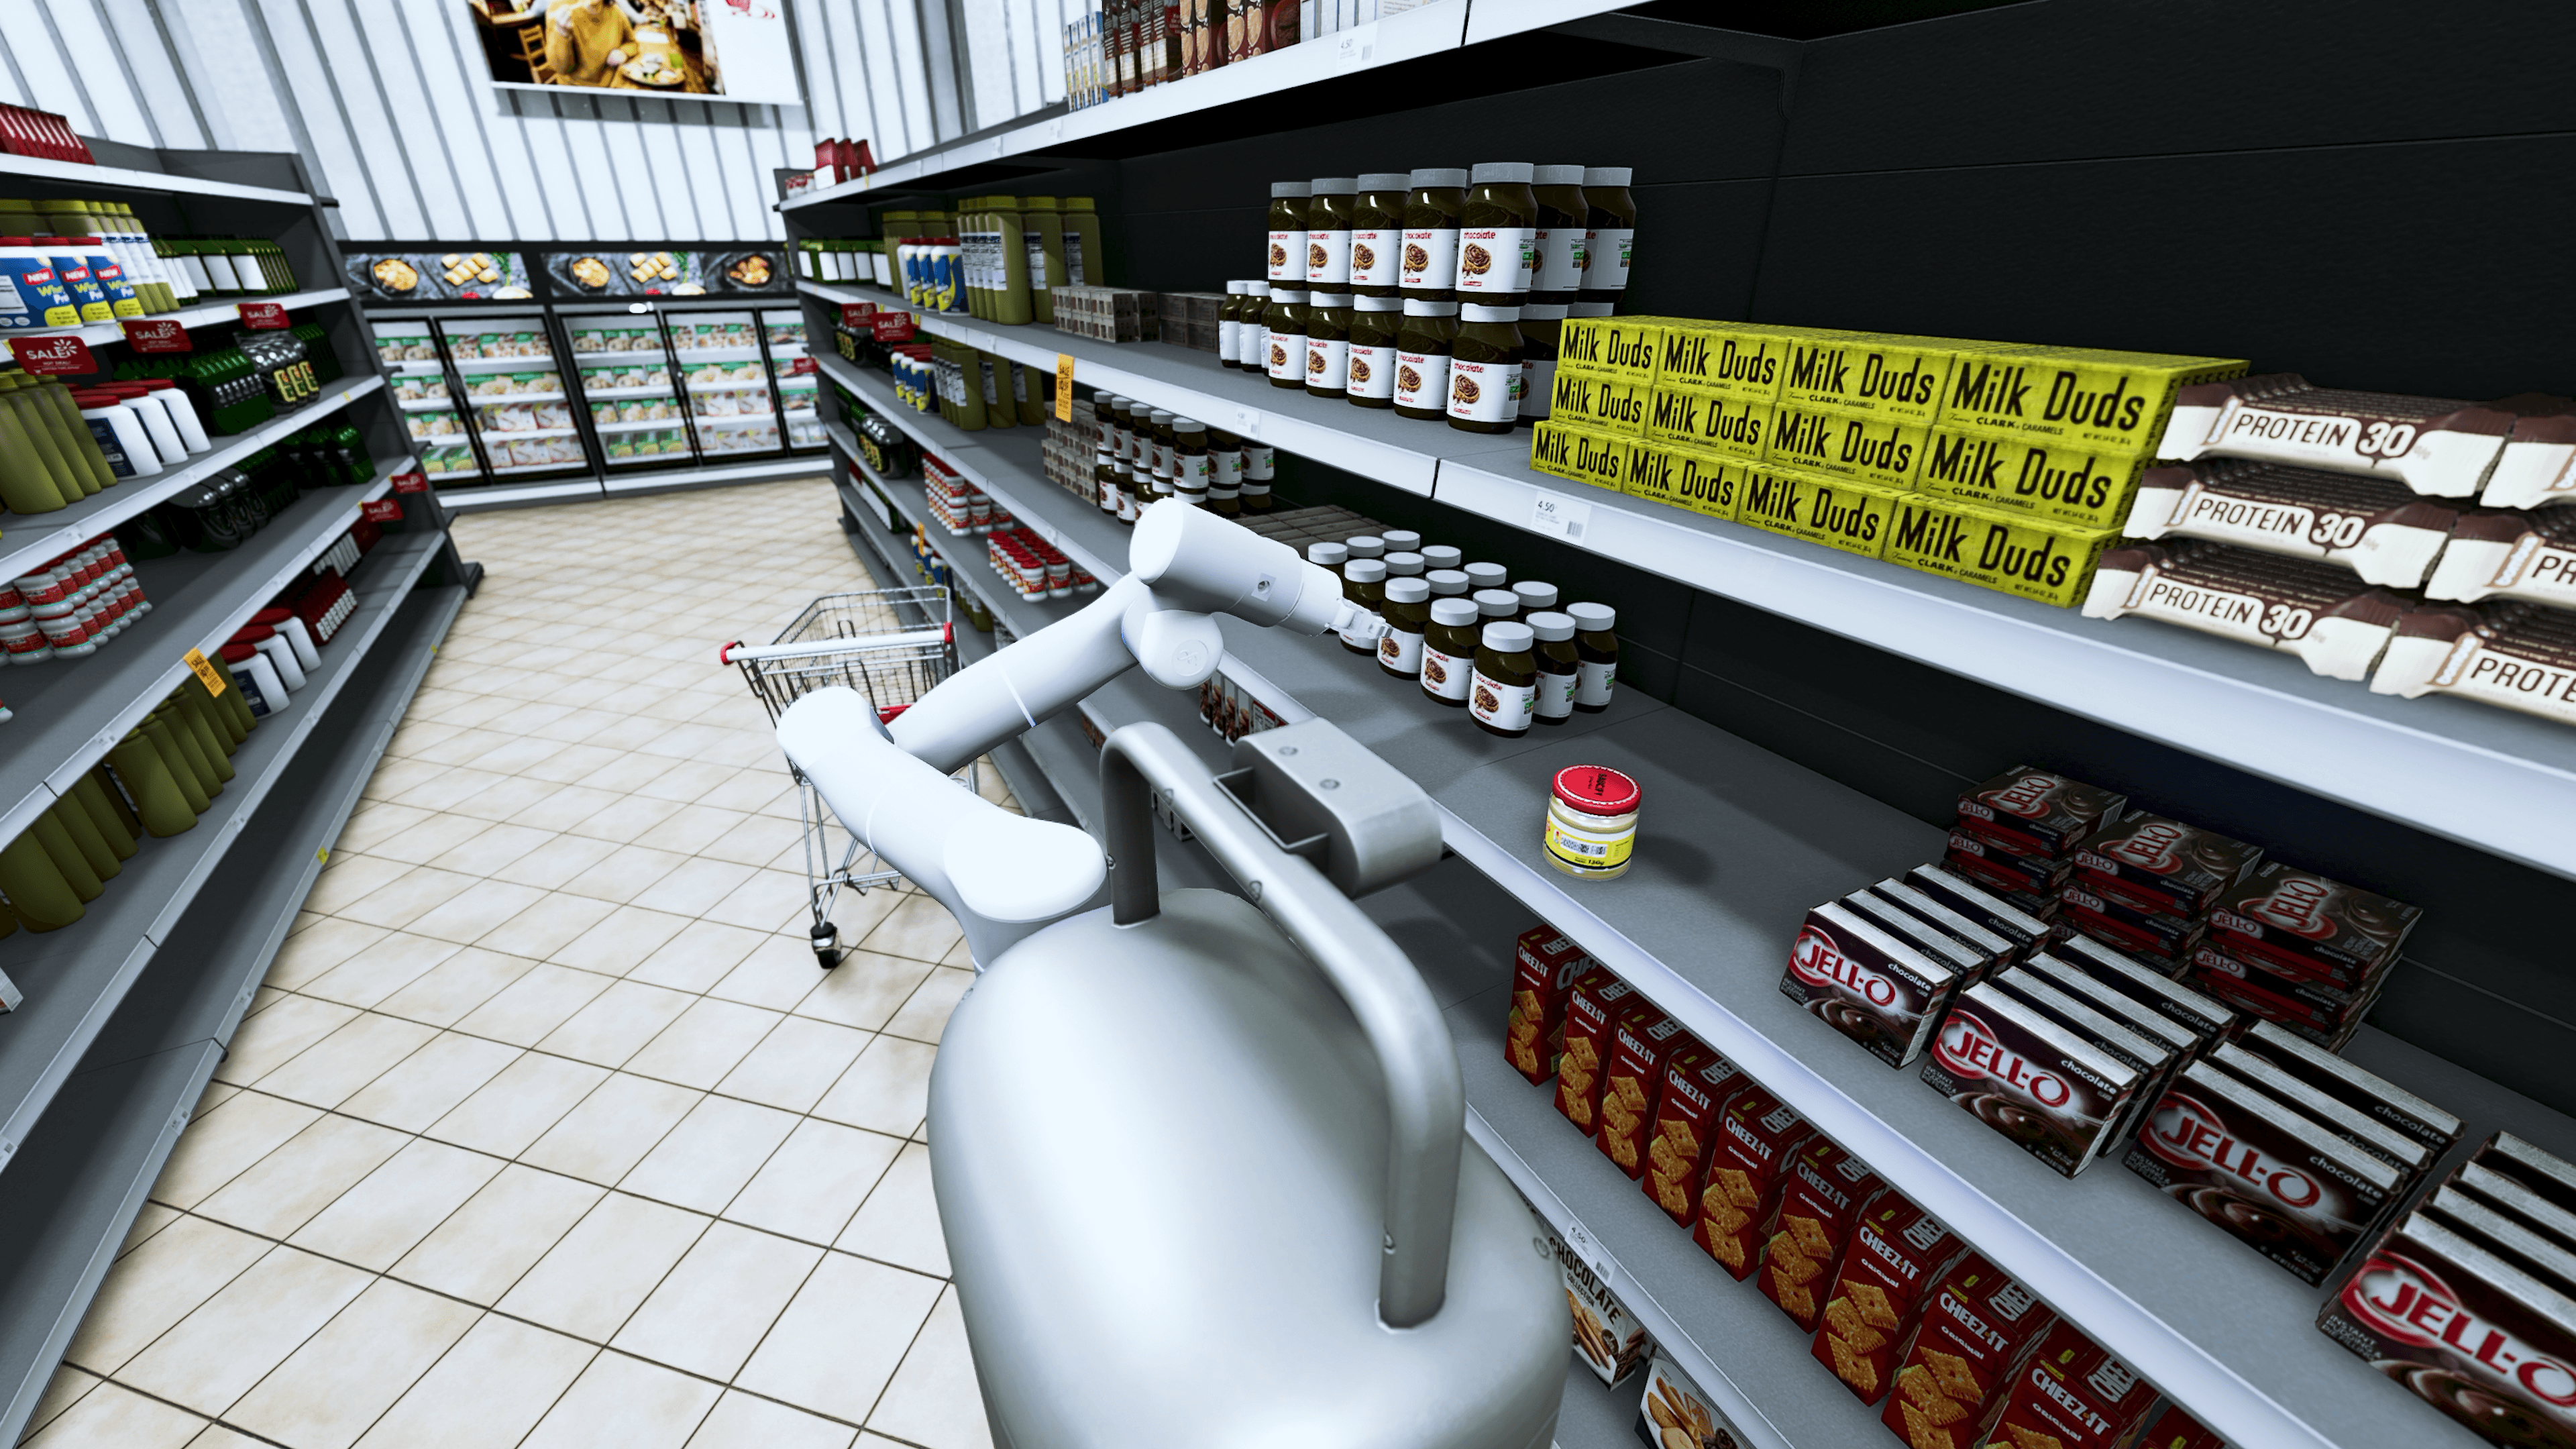
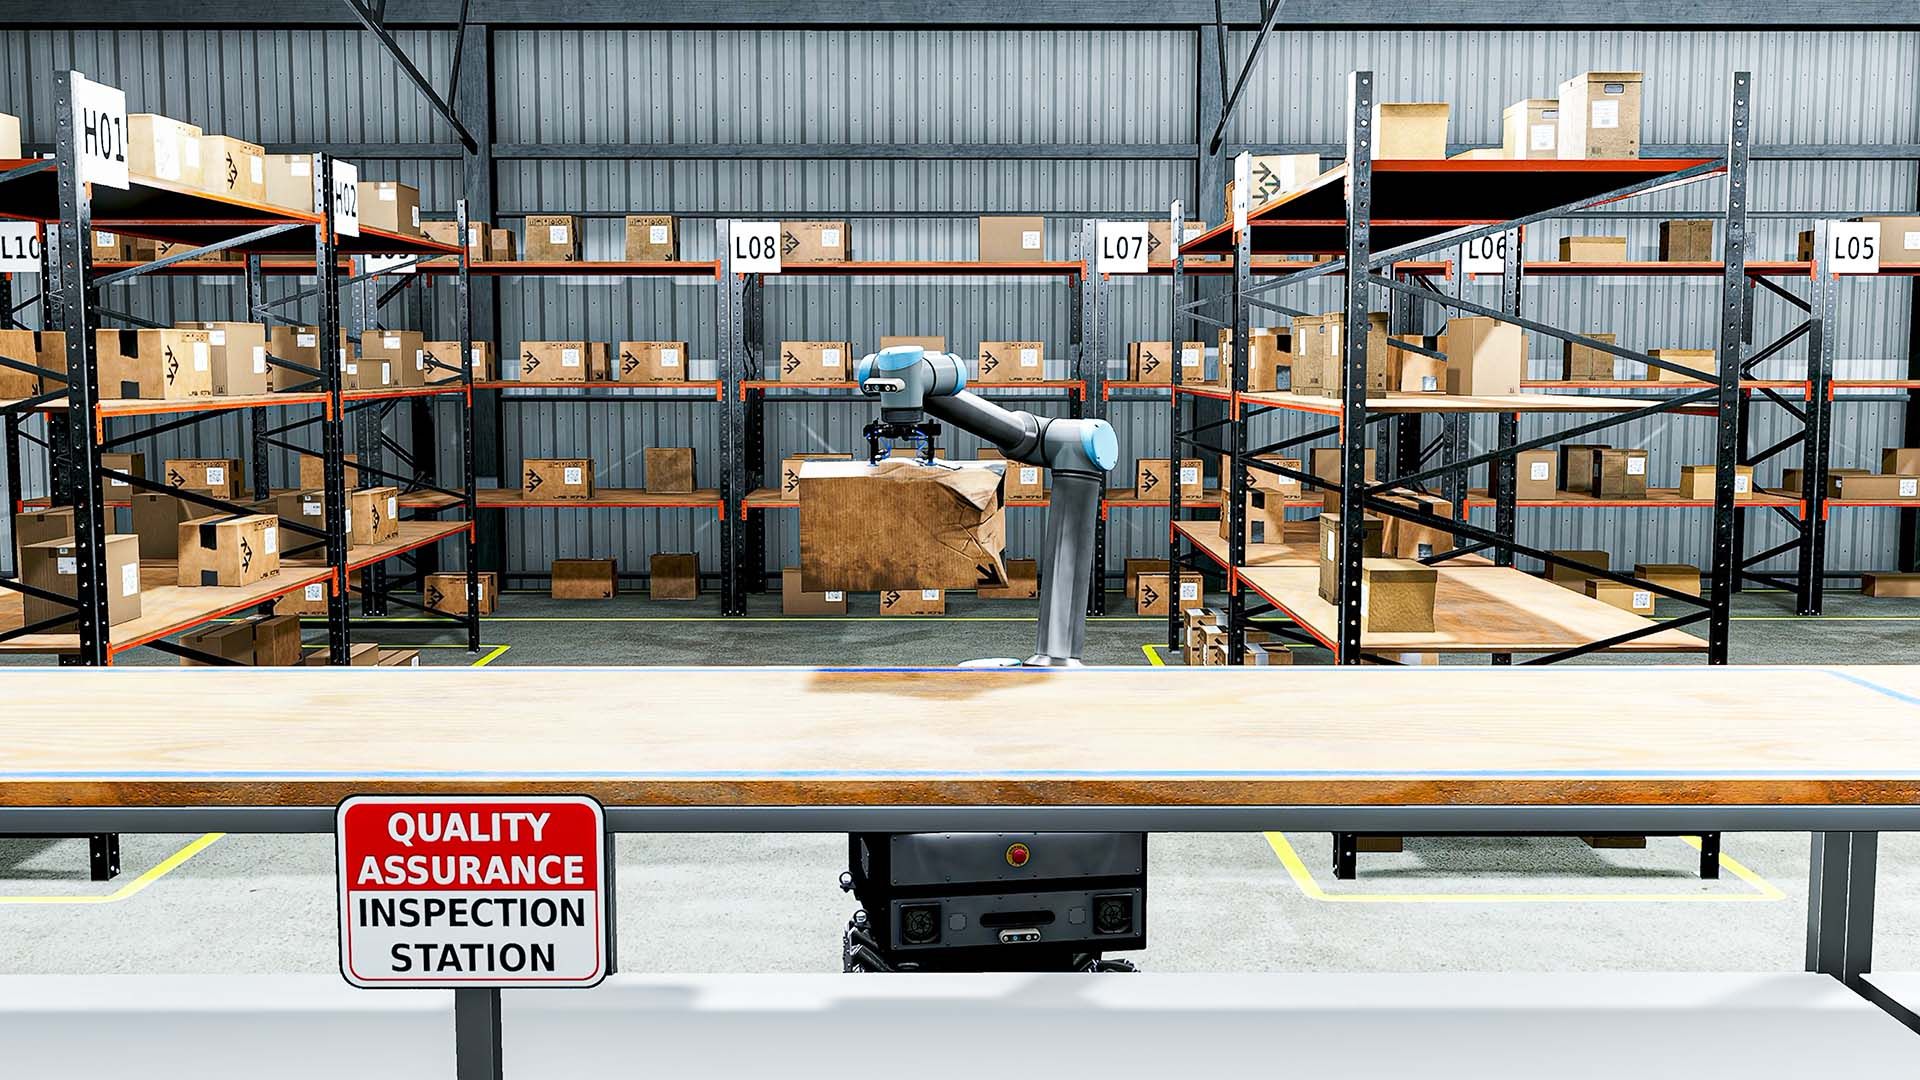
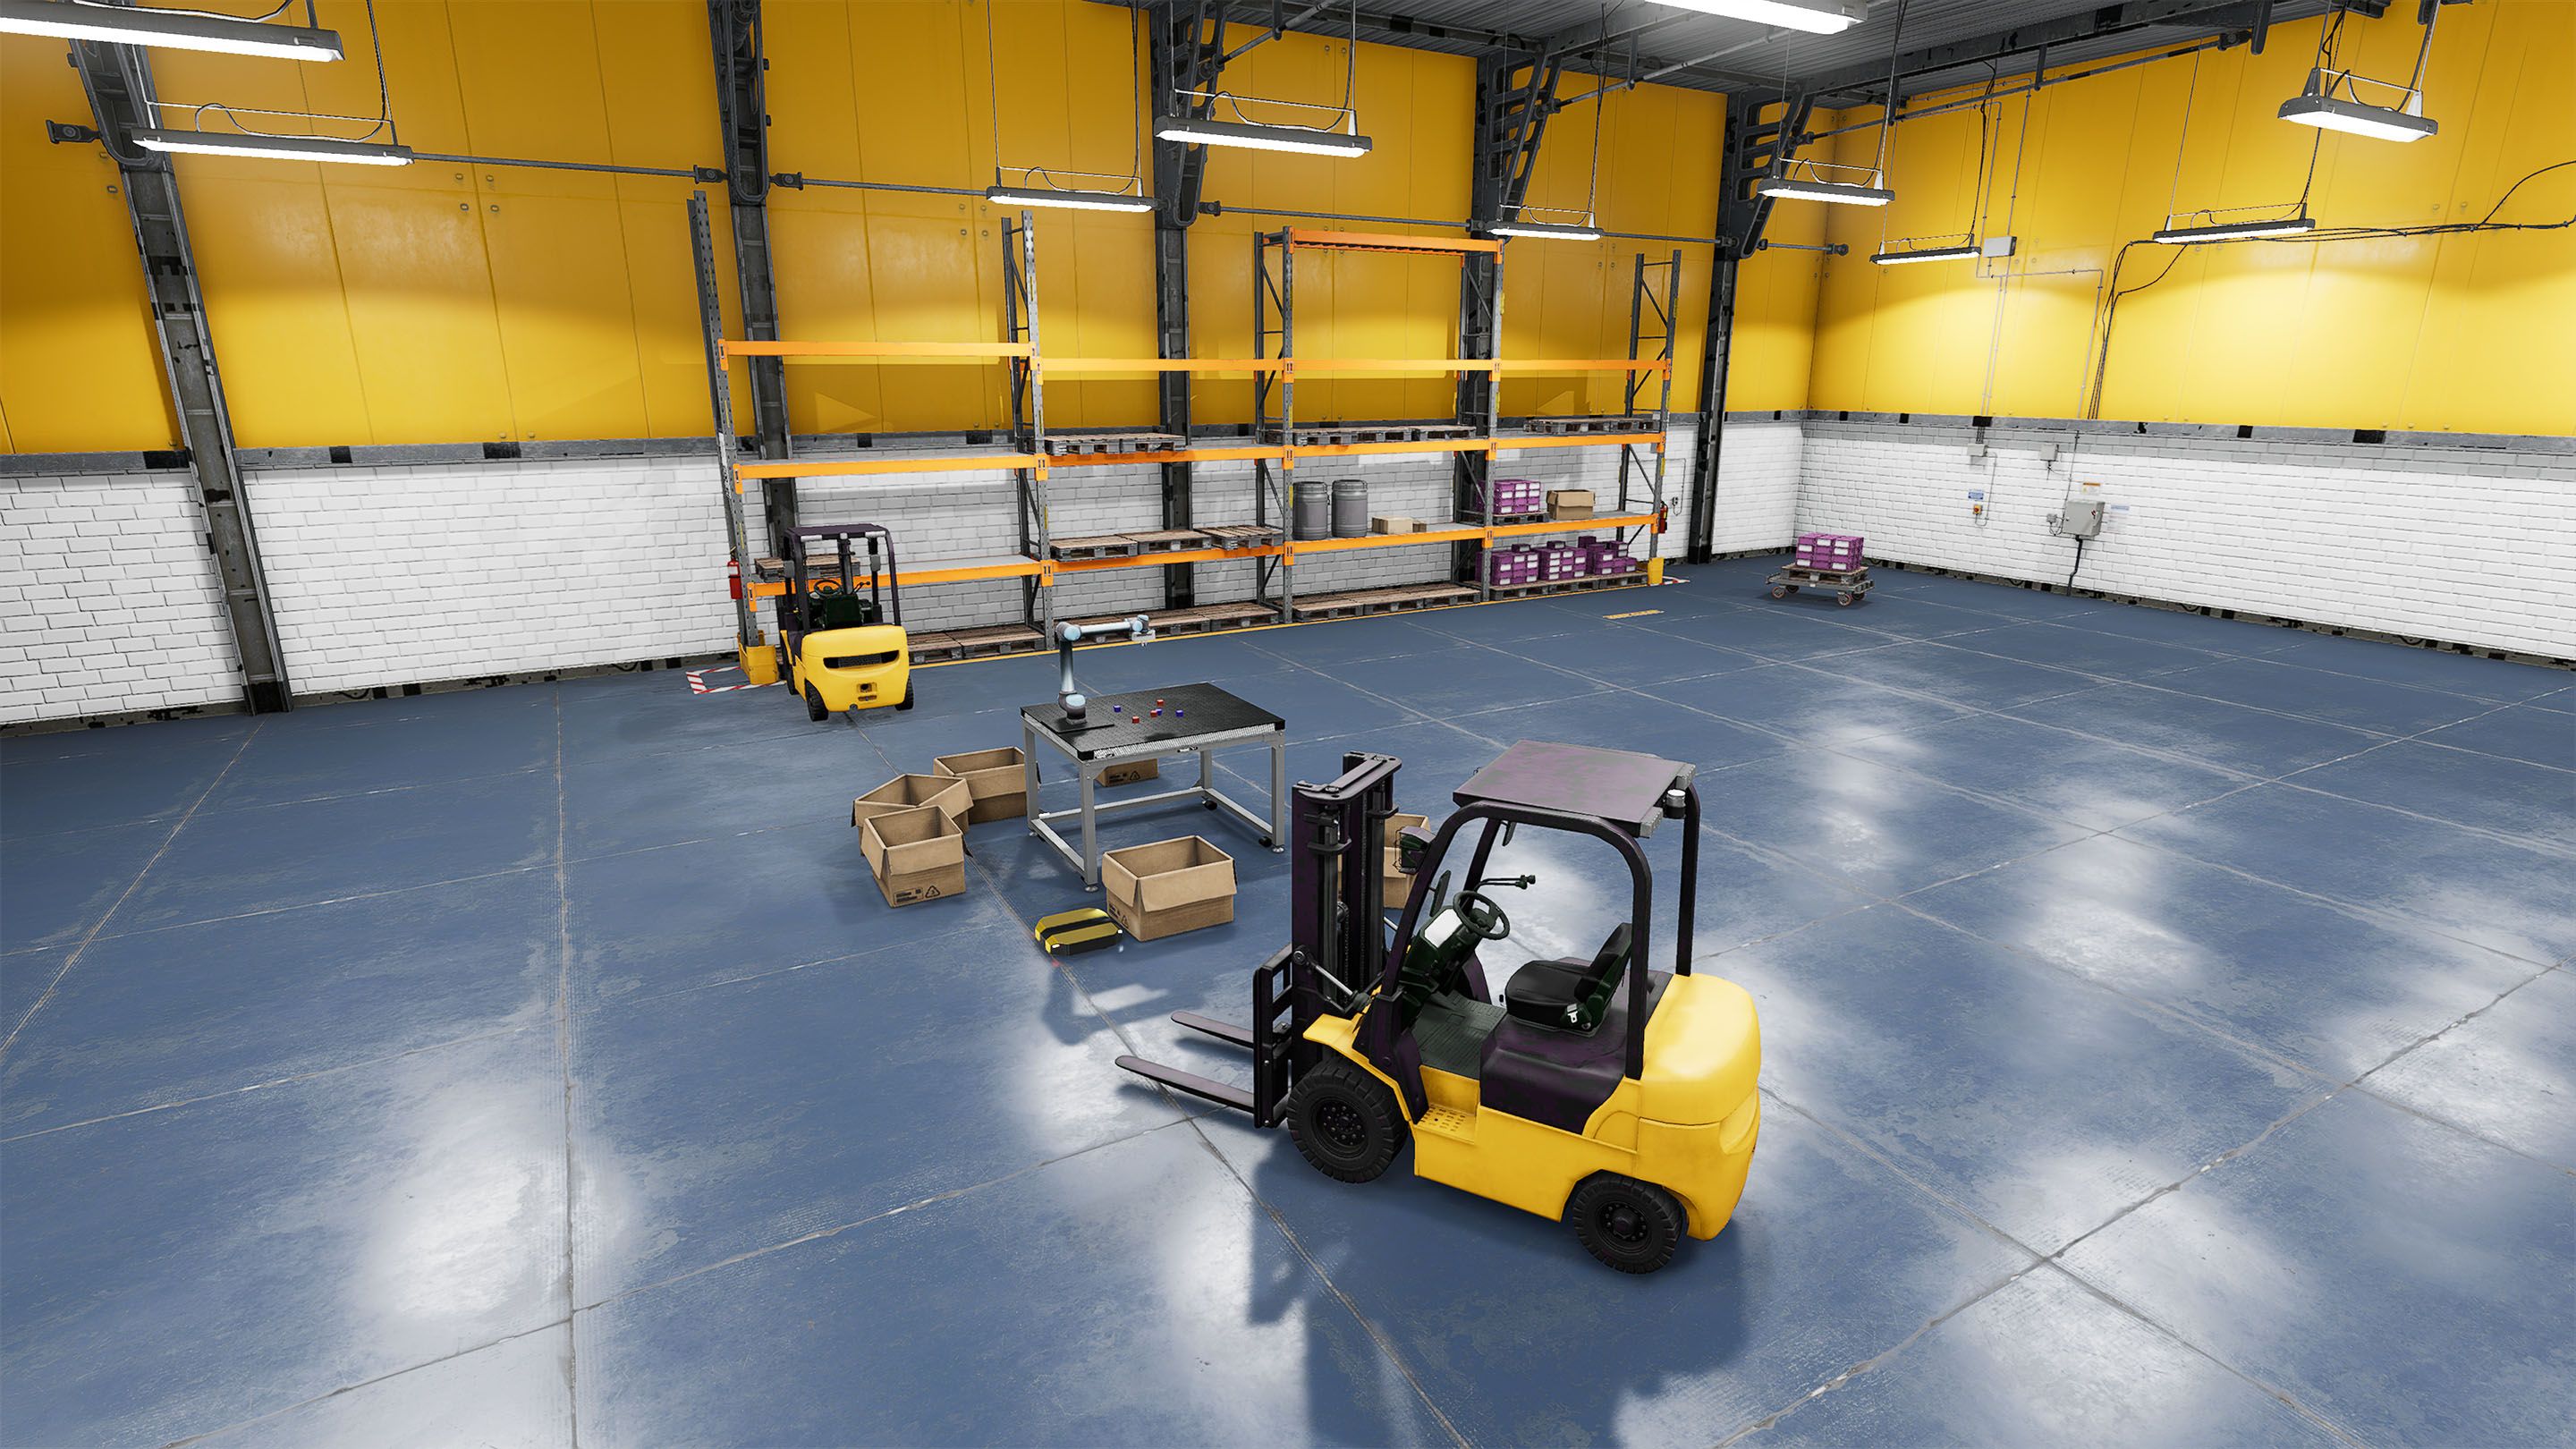
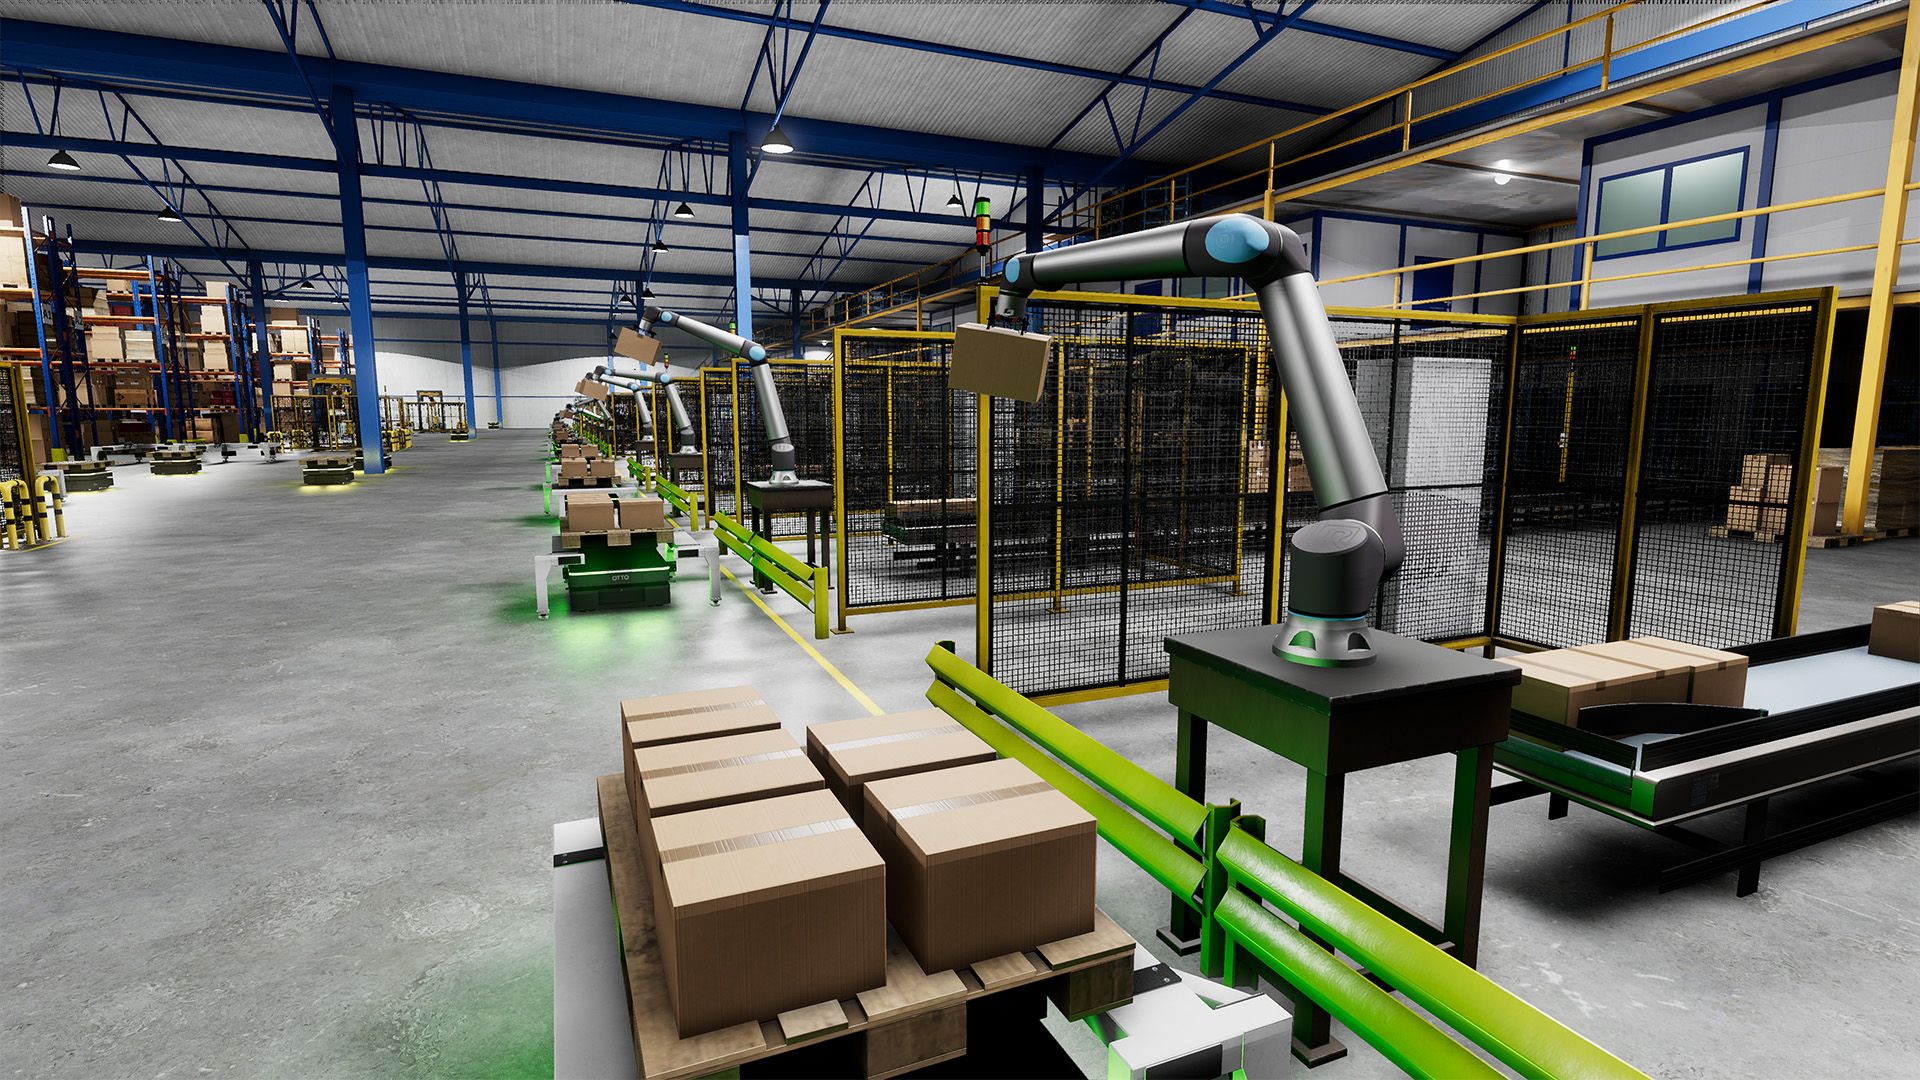
- Realistic Robotics Environment: Developed a warehouse-style scene featuring navigable layouts, objects, physics, and lighting optimized for robotics perception and mapping.
- Multi-Robot Setup: Implemented multiple differential-drive robots with onboard sensors (LiDAR, camera, IMU), demonstrating coordinated navigation and ROS 2-based autonomy.
- Cloud-Scalable Architecture: Designed the simulation to run efficiently on AWS compute instances, showcasing O3DE’s potential for distributed or large-scale simulation workloads.
- Open-Source Demonstration: Published the project as a public reference demo (ROSCon 2023) to support the broader robotics community adopting O3DE + ROS 2.
Results
The AWS + Robotec.ai collaboration successfully demonstrated a highly scalable robotics simulation.
Key outcomes:
- Modern tech stack with huge performance and scalability advantage at a fraction of infrastructure costs.
- Multi-robot simulations suitable for cloud-based workloads and CI/CD pipelines.
- High performance GPU LiDAR and camera simulation powered by O3DE and RGL.
- Seamless ROS 2 integration, enabling navigation, mapping, and autonomy testing out of the box.
- An open, reusable reference implementation supporting developers adopting O3DE for robotics.
- A successful showcase, demonstrating how AAA-grade graphics engines and robotics frameworks can converge.